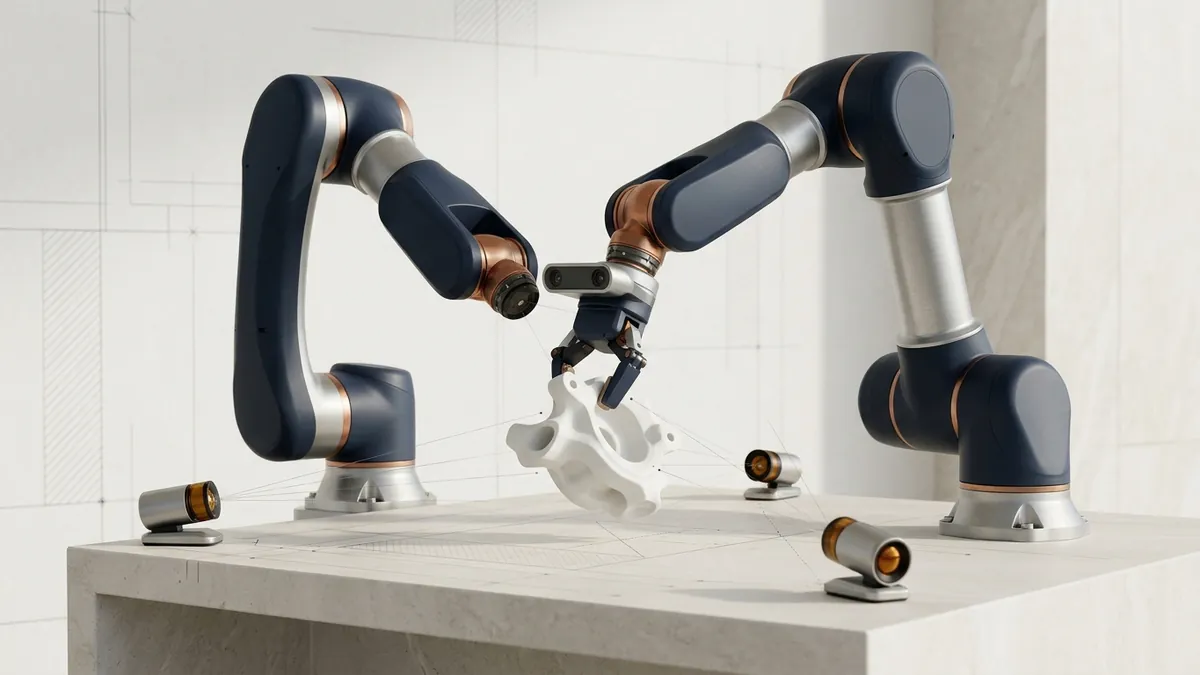
Cognitive Industrial Robotics & 3D Vision · 2026-11-02
Cognitive Industrial Robotics: Eliminating Weeks of Teach-Pendant Programming with 6-DoF Vision and 3-Agent Safety Consensus
How VeroSpatial and VeroReason enable industrial robot manipulators to perceive unstructured 3D workcells without rigid jigs and synthesize collision-free trajectories in under 2 seconds through a three-agent consensus between a Planner, Physics Verifier, and Safety Auditor.
Architectural Pillars & Implementation Blueprint
1. The Bottleneck of High-Mix Manufacturing: Reprogramming industrial robots manually via teach pendants takes weeks whenever product geometry changes.
2. Fixtureless 6-DoF Spatial Perception (VeroSpatial): Fusing depth point clouds and vision models to lock onto part poses in real time, even when parts shift on the conveyor.
3. Deterministic Safety via 3-Agent Consensus (VeroReason): Separating trajectory planning from inverse-kinematics physics verification and hard safety envelope auditing.
4. Sub-2-Second Product Changeovers: Switching production lines between product variants in seconds without shutting down the factory.